Joint Space Mass Matrix
R2026bJoint-space mass matrix for robot configuration
Joint Space Mass Matrix block

To add a block to a model, double-click the canvas and start typing the block name. Then, select the block from the list.
Libraries:
Robotics System Toolbox /
Manipulator Algorithms
Description
The Joint Space Mass Matrix block returns the joint-space mass matrix for the given robot configuration (joint positions) for the Rigid body tree robot model.
Examples
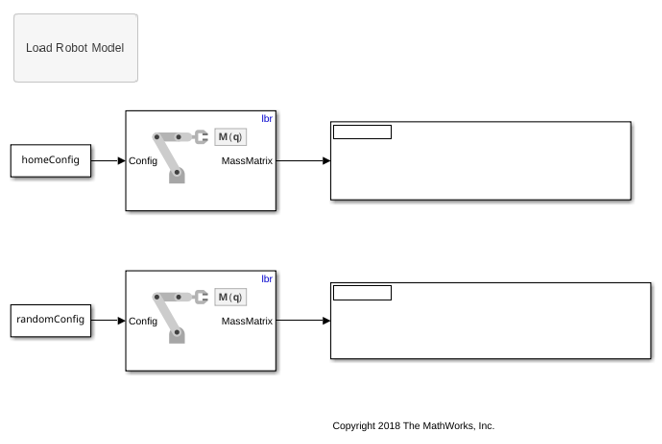
Get Mass Matrix for Manipulators in Simulink
Calculate the mass matrix for robot manipulators using a rigid body tree robot model passed to manipulator algorithm blocks in Simulink®.
Ports
Input
Output
Parameters
Programmatic Use: Add Block
To add the block programmatically, use the add_block function with one of these library block paths as the source.
"robotmaniplib/Joint Space Mass Matrix"
Example: add_block("robotmaniplib/Joint Space Mass Matrix","myModel/myBlock",MakeNameUnique="on")
Extended Capabilities
Version History
Introduced in R2018a

